Back to all instances

Scissor

Benchmark instance 070
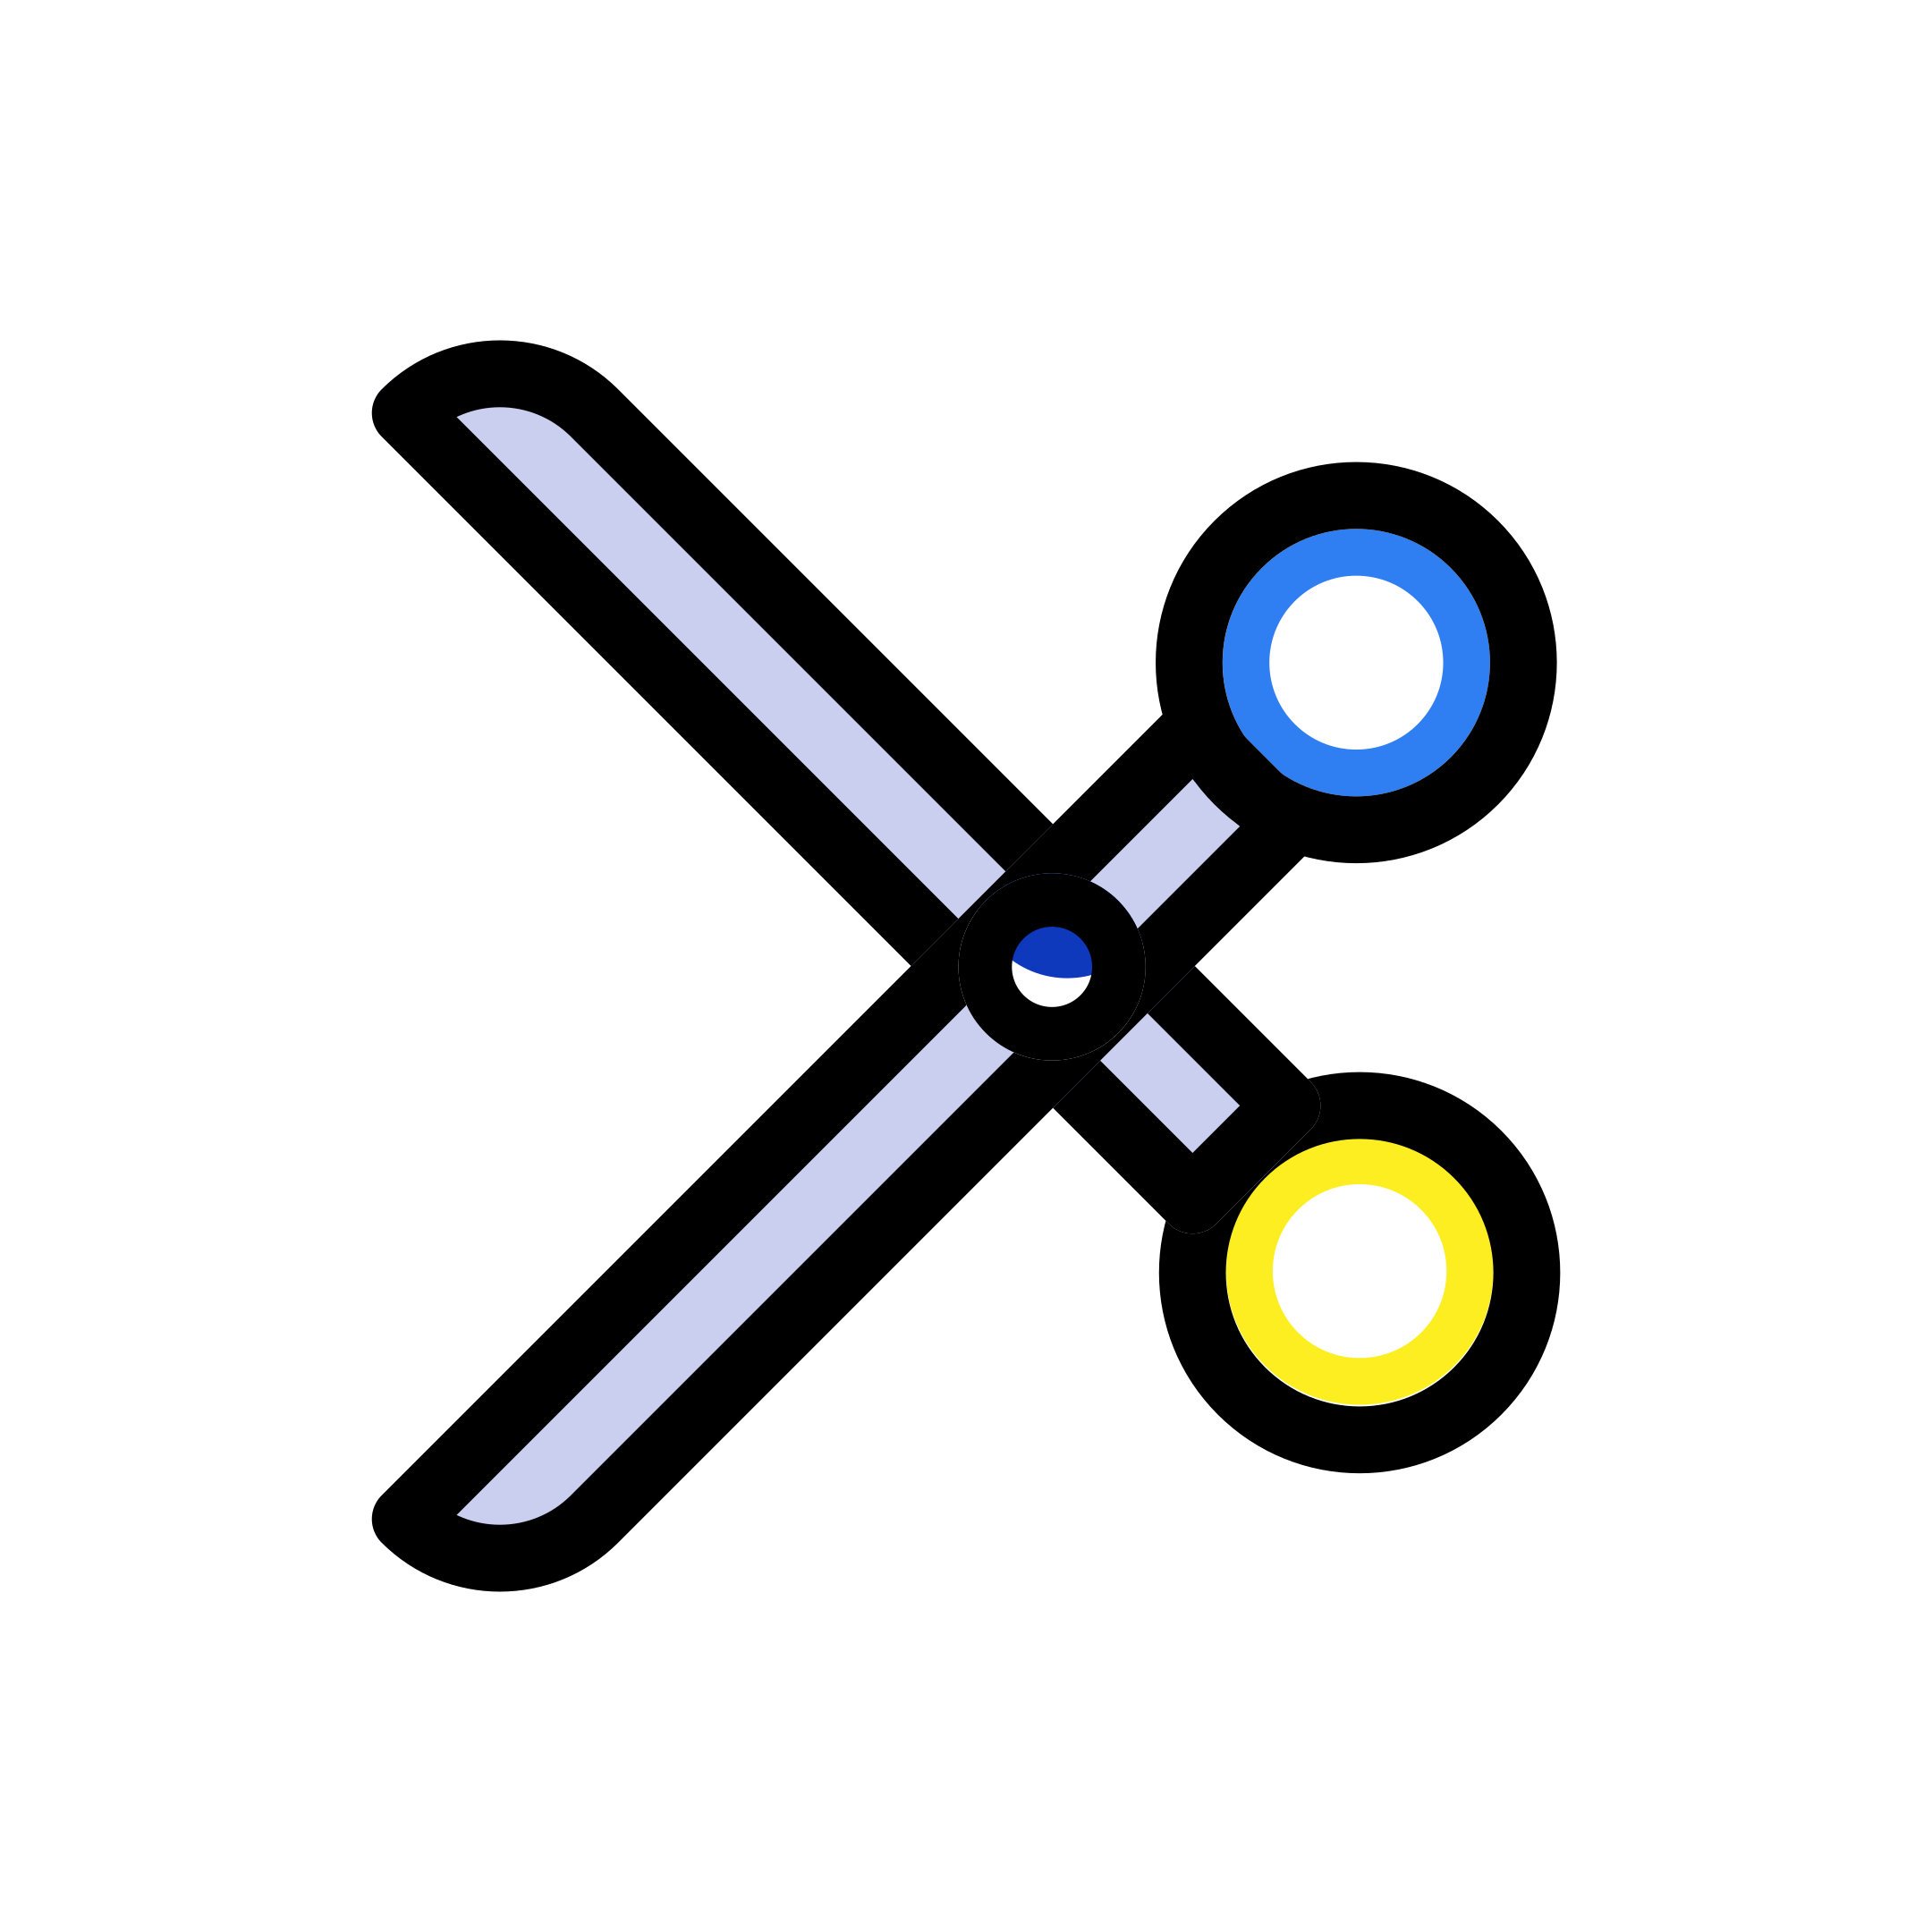
Input static SVG
Input static SVG for Scissor
Source Lottie animation
Motion edit prompt

Treat the scissors as two rigid halves hinged at the central screw. From the open crossed pose in the provided SVG, rotate the upper blue-handled half clockwise around the screw while simultaneously rotating the lower yellow-handled half counterclockwise around the same pivot, so the long blades swing together into a nearly closed, almost horizontal overlap. Ease the motion smoothly, hold the closed snip very briefly, then reverse both halves along the same paths until they return to the original open crossed pose. Keep the central screw cap fixed in place on top of the rotating arms, with no scaling, fading, or deformation.

Example model outputs

Human-approved

Claude Opus 4.8

Reasoning effort: extra-high

Verification report: 8 passed · 0 failed
Result Check
PASS ver_artwork_and_opacity_preserved

Paint, opacity and unclipped artwork stay unchanged

Measured values
{
  "alpha_change": 0.0,
  "clipped_fraction_change": 0.0,
  "stroke_change": 0.0008999999999872443
}
PASS ver_eased_brief_hold

Eased strokes share a short stopped snip before the return

Measured values
{
  "closed_source_frames": [
    [
      40,
      50
    ],
    [
      40,
      50
    ]
  ],
  "paces_per_column": [
    [
      [
        0.36914558486122523,
        2.5047192558587956,
        0.4071572306086399
      ],
      [
        0.4071572306086399,
        2.5047192558587956,
        0.3691455848612252
      ]
    ],
    [
      [
        0.3885913121985739,
        2.636566041222909,
        0.428608495320527
      ],
      [
        0.428608495320527,
        2.636566041222909,
        0.3885913121985739
      ]
    ]
  ]
}
PASS ver_nearly_closed_overlap

The tips overlap while the two halves have not merged completely

Measured values
{
  "contour_uncertainty": 1.9240104253556183,
  "distal_gap": -33.40317332229165,
  "source_frame": 42,
  "yellow_exposure": 23.387038648567056
}
PASS ver_opposed_snip_and_reverse

Closing and reopening each overlap in time, without requiring equal progress

Measured values
{
  "sweeps": [
    38.0001,
    40.0004
  ]
}
PASS ver_original_open_pose

Both endpoint poses match the original open scissors

Measured values
{
  "max_anchor_error": 0.0
}
PASS ver_rigid_halves

Rigid registration of blade and handle together, without scale

Measured values
{
  "max_error": 0.007137006401243785
}
PASS ver_screw_fixed_on_top

Screw remains stationary above both arms

Measured values
{
  "motion": 0.0
}
PASS ver_shared_screw_hinge

Both stationary hinge points lie at the same screw joint

Measured values
{
  "hinge_drift": 0.0014949846905233525,
  "pivots": [
    [
      1176.1717935141558,
      1080.9956577839425
    ],
    [
      1176.171674775877,
      1080.9964212453588
    ]
  ],
  "screw_distances": [
    0.0007505865178146442,
    0.0007931888861332302
  ]
}

Human-rejected

Kimi K3

Reasoning effort: high

Verification report: 7 passed · 1 failed
Result Check
PASS ver_artwork_and_opacity_preserved

Paint, opacity and unclipped artwork stay unchanged

Measured values
{
  "alpha_change": 0.0,
  "clipped_fraction_change": 0.0,
  "stroke_change": 0.0007999999999981355
}
PASS ver_eased_brief_hold

Eased strokes share a short stopped snip before the return

Measured values
{
  "closed_source_frames": [
    [
      37,
      49
    ],
    [
      37,
      49
    ]
  ],
  "paces_per_column": [
    [
      [
        0.31782636707714784,
        2.1355730056857887,
        0.35409217479659805
      ],
      [
        0.321884048288282,
        1.9166965667682625,
        0.30599585239870153
      ]
    ],
    [
      [
        0.32007508929584993,
        2.149362029812883,
        0.35584621118596643
      ],
      [
        0.32348612562137574,
        1.9278758040367459,
        0.3081965608912082
      ]
    ]
  ]
}
FAIL ver_nearly_closed_overlap

The tips overlap while the two halves have not merged completely

Measured values
{
  "contour_uncertainty": 1.5922919706733865,
  "distal_gap": 243.7614757097956,
  "source_frame": 39,
  "yellow_exposure": 171.68489887908947
}
PASS ver_opposed_snip_and_reverse

Closing and reopening each overlap in time, without requiring equal progress

Measured values
{
  "sweeps": [
    29.9433,
    30.1264
  ]
}
PASS ver_original_open_pose

Both endpoint poses match the original open scissors

Measured values
{
  "max_anchor_error": 0.0
}
PASS ver_rigid_halves

Rigid registration of blade and handle together, without scale

Measured values
{
  "max_error": 0.006777115297721428
}
PASS ver_screw_fixed_on_top

Screw remains stationary above both arms

Measured values
{
  "motion": 0.0
}
PASS ver_shared_screw_hinge

Both stationary hinge points lie at the same screw joint

Measured values
{
  "hinge_drift": 0.001421033430263386,
  "pivots": [
    [
      1175.5006980388644,
      1078.0010787924111
    ],
    [
      1175.5005995327222,
      1077.999031328579
    ]
  ],
  "screw_distances": [
    3.0694194171701015,
    3.0714388304260445
  ]
}